

Physical Intelligence
A research-heavy foundation model designed to provide robots with general-purpose motor skills, best for hardware manufacturers and advanced labs rather than immediate industrial deployment.
Excellent for cross-platform robotic control and complex physical reasoning, weaker for teams needing turnkey, out-of-the-box automation.
Analysis based on product data, pricing structure, traffic signals, and public user sentiment.
Who Should Use Physical Intelligence?
Typical users
Robotics researchers, hardware OEMs, and advanced automation engineers at scaling startups or enterprise R&D labs.
Maturity fit
advanced
Choose this if…
- You need a single model to control diverse robotic hardware (arms, mobile bases, grippers).
- Your priority is general-purpose dexterity over high-speed, repetitive task execution.
- You want to move away from hard-coded, task-specific robotics programming.
Skip this if…
- You need a finished product for immediate warehouse or factory floor use.
- Your workflow requires sub-millisecond latency that large VLA models cannot yet guarantee.
- You lack the internal engineering capacity to integrate and fine-tune foundation models.
About Physical Intelligence
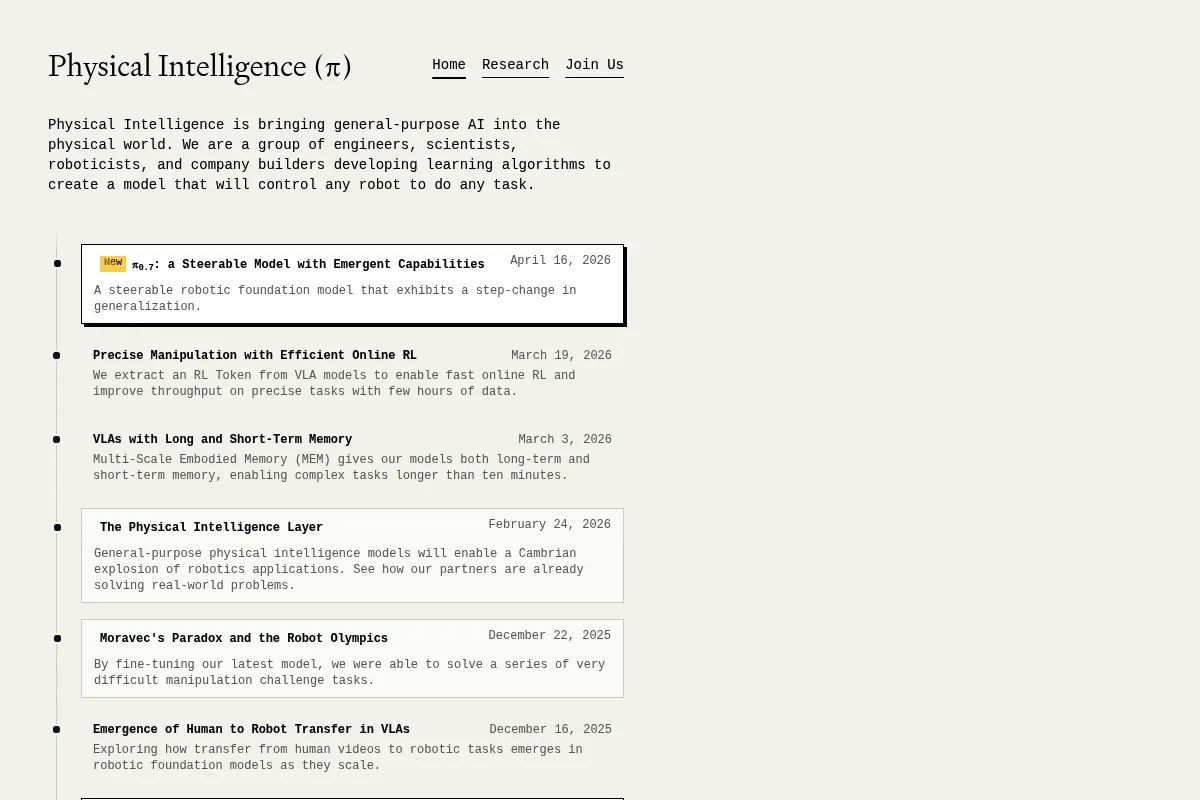
Physical Intelligence (Pi) develops universal foundation models for robotic control. Founded by pioneers from Google DeepMind and Stanford, the company aims to create a 'brain' for any robot, enabling machines to learn physical tasks through data rather than manual programming.
Official profiles
What it actually does
The core product, π0 (pi-zero), is a Vision-Language-Action (VLA) model. It ingests visual data and text instructions to output precise motor commands, allowing robots to perform multi-step tasks like folding laundry, clearing tables, or boxing items across different hardware platforms.
What makes it different
Unlike competitors building proprietary hardware (like Tesla or Figure), Pi is hardware-agnostic. Their model is trained on the 'Open X-Embodiment' dataset and proprietary data, focusing on the software intelligence layer that can be ported to almost any physical form factor.
Key Features
π0 Model Architecture
A large-scale model that translates camera feeds and text into robot actions.
Hardware Agnosticism
Compatible with various robotic arms, mobile platforms, and end-effectors.
Physical Reasoning
Understands how to interact with complex, non-rigid objects like laundry or trash.
Scaling Law Application
Uses massive datasets to improve performance, similar to how LLMs improve with more text.
Pre-trained Foundation
Reduces the need for thousands of hours of task-specific training data.
Real-time Inference
Designed to run on-device or via low-latency cloud connections for reactive movement.
Pricing
Contact Sales
- Access to π0 models
- Custom fine-tuning support
- Hardware integration consulting
- Early access to research updates
Pricing checked 5 months ago
Pricing guidance
- When moving from simulation to real-world hardware testing
- When requiring proprietary fine-tuning on specific industrial data
- Model weights are not open-source
- Requires high-end NVIDIA hardware for local inference
Premium, research-led positioning aimed at high-capital robotics companies and labs.
Pros & Cons
Strengths
-
Broad generalization capabilities
The model can handle tasks it wasn't specifically programmed for by drawing on its massive training set of physical interactions.
-
Reduces development overhead
Engineers can use natural language or visual demonstrations to 'teach' robots instead of writing complex kinematic code.
-
Superior handling of 'messy' environments
Excels at tasks involving soft goods and unpredictable layouts where traditional computer vision often fails.
-
Top-tier research pedigree
The team includes the creators of many foundational robotics AI papers, ensuring the tech is at the absolute limit of what is possible.
Weaknesses
-
High compute requirements
Running large VLA models requires significant GPU resources, which may be cost-prohibitive for small-scale deployments.
Affects: Startups and edge-computing applications
-
Not a turnkey solution
This is a model, not a robot. You still need to provide the hardware and handle the integration layer yourself.
Affects: Non-technical operators and small businesses
-
Early-stage commercial availability
The technology is currently more of a research breakthrough than a stable, supported commercial product with SLAs.
Affects: Enterprise production environments
Real User Sentiment
The robotics community is highly optimistic about the model's ability to handle complex physics, though skeptical about near-term reliability in safety-critical environments.
Users tend to like
- Ability to fold laundry and handle soft objects
- Hardware-agnostic approach
- The pedigree of the founding team
- The move toward 'General Purpose' rather than 'Single Purpose' robots
Users commonly complain about
- Lack of public access to models
- High latency in early demonstrations
- Dependence on massive amounts of high-quality data
Recurring tradeoffs
- Users trade the precision and speed of hard-coded automation for the flexibility and reasoning of a foundation model.
Happiest users
Robotics researchers who want to push the boundaries of what autonomous systems can do without building models from scratch.
Often frustrated
Industrial engineers looking for a 'plug-and-play' solution to replace traditional PLC-based automation today.
Use Cases
Hospitality
Automating laundry folding and sorting in large-scale hotel operations.
E-commerce
Developing robots that can pick and pack irregularly shaped items in warehouses.
Lab Automation
Using robotic arms to handle delicate glassware and chemicals via natural language instructions.
Hardware R&D
Testing new robotic limb designs using a pre-trained 'brain' to evaluate physical capabilities.
Home Assistance
Researching general-purpose robots capable of clearing tables and tidying rooms.
Frequently Asked Questions
Is Physical Intelligence's model open source?
No, the π0 model is proprietary. However, the founders have historically contributed significantly to open datasets like Open X-Embodiment, which others can use to train their own models.
How much does it cost to use Physical Intelligence?
Pricing is not public. As a high-growth AI startup, they currently operate through strategic partnerships and enterprise contracts. Expect high costs associated with compute and integration.
Does it work with any robot?
It is designed to be hardware-agnostic. It has been demonstrated on various platforms, including the Unitree H1 humanoid, various robotic arms, and mobile bases, provided they can interface with the model's VLA outputs.
How does π0 compare to Google's RT-2?
π0 is a successor in spirit, built by many of the same researchers. It aims for higher dexterity and better handling of complex physics (like liquids or fabrics) compared to earlier iterations of Vision-Language-Action models.
Can I use this for high-speed factory assembly?
Probably not yet. Foundation models like π0 prioritize reasoning and generalization over the millisecond-perfect repeatability required for high-speed automotive assembly lines.
What are the hardware requirements to run the model?
While specific specs aren't public, these models typically require powerful NVIDIA GPUs (like A100s or H100s) for inference if you want to maintain the reactivity needed for physical interaction.
Why trust this page?
This evaluation combines product positioning, pricing analysis, traffic and market signals, and public user sentiment into a single decision-support page. Content is generated editorially — not copied from the vendor's website.
Funding & Company
Founded
2024
Stage
Series b
Total Raised
$1.07B
Latest Round
Series B (Nov 2025)
Notable Investors
Physical Intelligence has raised a total of $1.07 billion across three significant funding rounds in under two years, indicating exceptionally strong investor confidence. This rapid capital influx from top-tier investors like Jeff Bezos, OpenAI, and CapitalG provides a substantial runway to pursue its ambitious goal of creating general-purpose AI for robotics.
Market Signals & Traffic
Estimated visits, global rank, geography, traffic sources, monthly visit trends, and organic search keywords (Similarweb)—on a dedicated page built for depth and search.
- Estimated visits
- 0
- Global rank
- —
- Snapshot
- May 2026
- Traffic trend
- Falling
Estimated monthly visits
Alternatives to Physical Intelligence
View all alternativesVeo
Video Creation, Content Creation, AI Assistant
AI model generating high-quality videos from text or image prompts.
Skild AI
Automation & Agents, Developer Tools
General-purpose foundation model for robotics and physical intelligence.
Similar Tools
Unitree
Automation & Agents, Developer Tools, Research
High-performance quadruped and humanoid robots for consumer and industrial applications.
Reka
Developer Tools, AI Assistant
Multimodal language models for text, image, video, and audio.
Obviously AI
Automation, Developer Tools, Research
No-code platform for building and deploying predictive machine learning models.
Velo AI
Health & Wellness, Security
Smart bike light and camera for real-time cyclist safety
Chatfuel
Marketing Automation, Communication, Automation
No-code chatbot platform for WhatsApp, Instagram, and Facebook Messenger.
Smol.ai
Developer Tools, Automation & Agents
Autonomous agent that generates entire codebases from simple markdown prompts.